// Machine learning · Computer vision · Robotics · AI agents

I build intelligent systems that

see · drive · fly learn · predict · speak measure · analyze · explain

From first commit to signed contract.

I build intelligent systems, and I stay with them until a customer is using them. So far that's meant training models, flying drones in a motion-capture lab, compiling Windows installers, and pricing the quote.

I'm VP of Engineering and Operations at Araca, a semiconductor wafer-polishing (CMP) equipment and services company in Tucson. I joined in February 2026 as a software engineer and built Araca Insights from scratch: an offline desktop app that turns polishing test data into analysis and reports, work Araca estimates at 35-95 hours per project by hand. It ships as a licensed product with an on-premises LLM agent, so customer data stays on site. Today I own that product line, lead our slurry flow program (4K, 240 fps polishing video turned into flow measurements with OpenCV and AI segmentation), and own revenue for two business units.

I finished my M.S. in Computer Science at the University of Arizona in May 2026. My thesis adapted a vision-language-action driving model to a new simulator and raised route coverage from 4.7% to 99.1%. I've published two peer-reviewed journal articles, one on drone swarm formation control and one on VR drone teleoperation. Before software, I spent five years running commercial operations for a food manufacturing group of about 500 people.

35-95h Manual work saved per project, by Araca's estimate
2 Peer-reviewed journal articles
Top 0.05% TCS CodeVita, 444,000+ participants
150% Revenue growth led, 2019 to 2021

What I bring to the table.

ML and LLM Systems

I train models that end up inside a product. I've fine-tuned a vision-language-action model with LoRA on one 16 GB GPU, trained prediction models with scikit-learn and FLAML AutoML, and built an on-premises LLM agent that answers questions about process data.

PyTorch PyTorch Lightning scikit-learn FLAML LoRA / PEFT LangChain Ollama

Computer Vision

Measurements out of video. I lead a program that turns 4K, 240 fps polishing footage into flow measurements with OpenCV and SAM 2.1 segmentation, plus FFT analysis to detect platen speed. In the lab I ran stereo SLAM on a ZED camera to rebuild a drone's surroundings in 3D.

OpenCV SAM 2.1 Hugging Face Transformers FFT analysis ZED SLAM

Robotics and Autonomous Systems

I've put controllers and links on real hardware: a decentralized formation controller on six Crazyflie quadrotors, a VR teleoperation link from a Meta Quest 3 to ROS 2 on a Jetson, and the camera and compute side of an interceptor drone on ArduPilot.

ROS 2 Crazyswarm2 Vicon ArduPilot / MAVLink Jetson Orin Raspberry Pi

Shipping Product and Running Operations

The work that starts once the code runs. I've shipped compiled Windows builds with an installer and node-locked license keys, and I led the license negotiation with the customer. I also handle quotes, pricing, hiring and revenue for two business units.

PySide6 / Qt Nuitka React Node.js AWS Docker Pricing and quotes Hiring

Selected projects.

Each one I built hands-on. Click through for the full case study.

Araca Insights

Creator and product owner

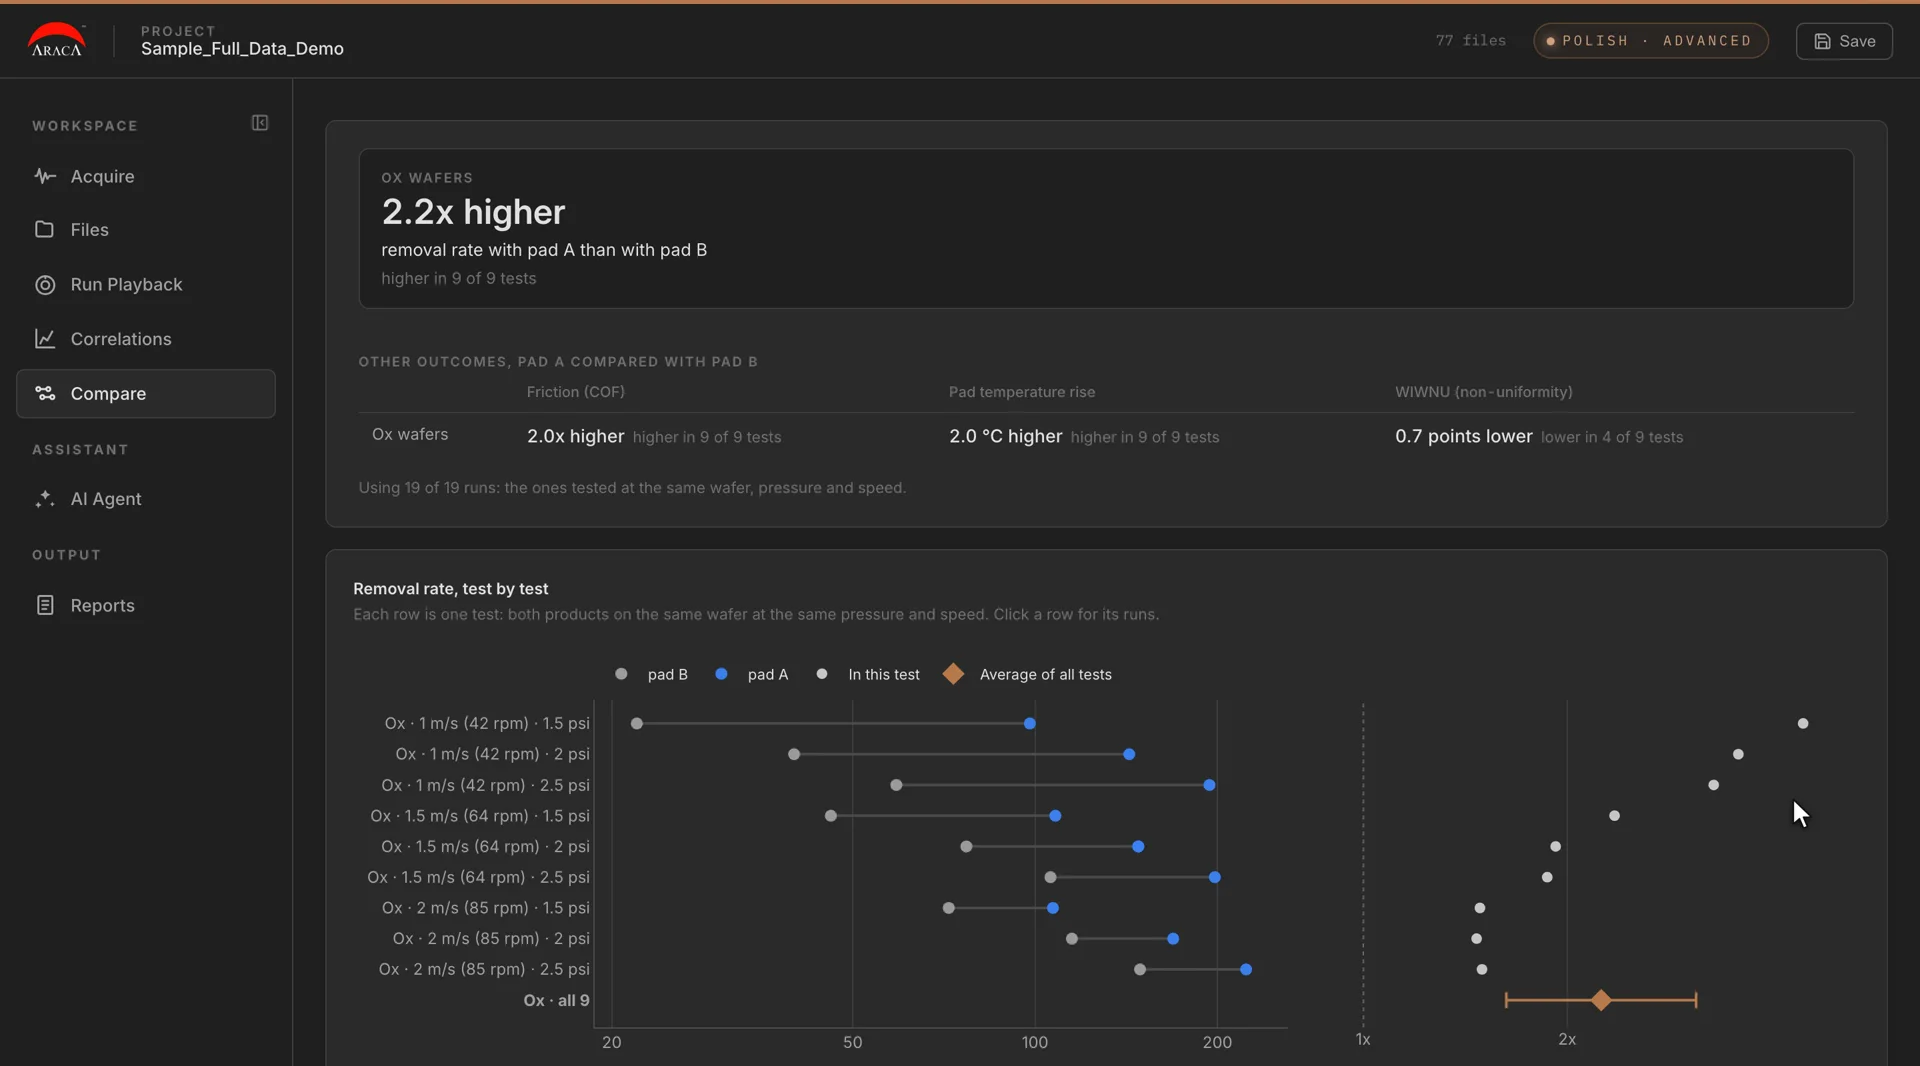
Offline desktop app for semiconductor polishing test data. It imports instrument files, plays back and compares runs, predicts process results, and exports Excel and PowerPoint reports, work Araca estimates at 35-95 hours per project by hand. I built it from scratch and shipped it as a licensed product, with an on-premises LLM agent that answers questions about the data.

35-95h Saved per project On-prem LLM agent Licensed Commercial product
PySide6 Dash scikit-learn FLAML LangChain Ollama
View case study
Araca Insights Compare view: removal rate for two pads compared test by test on sample data

VLA Autonomous Driving

M.S. thesis, University of Arizona

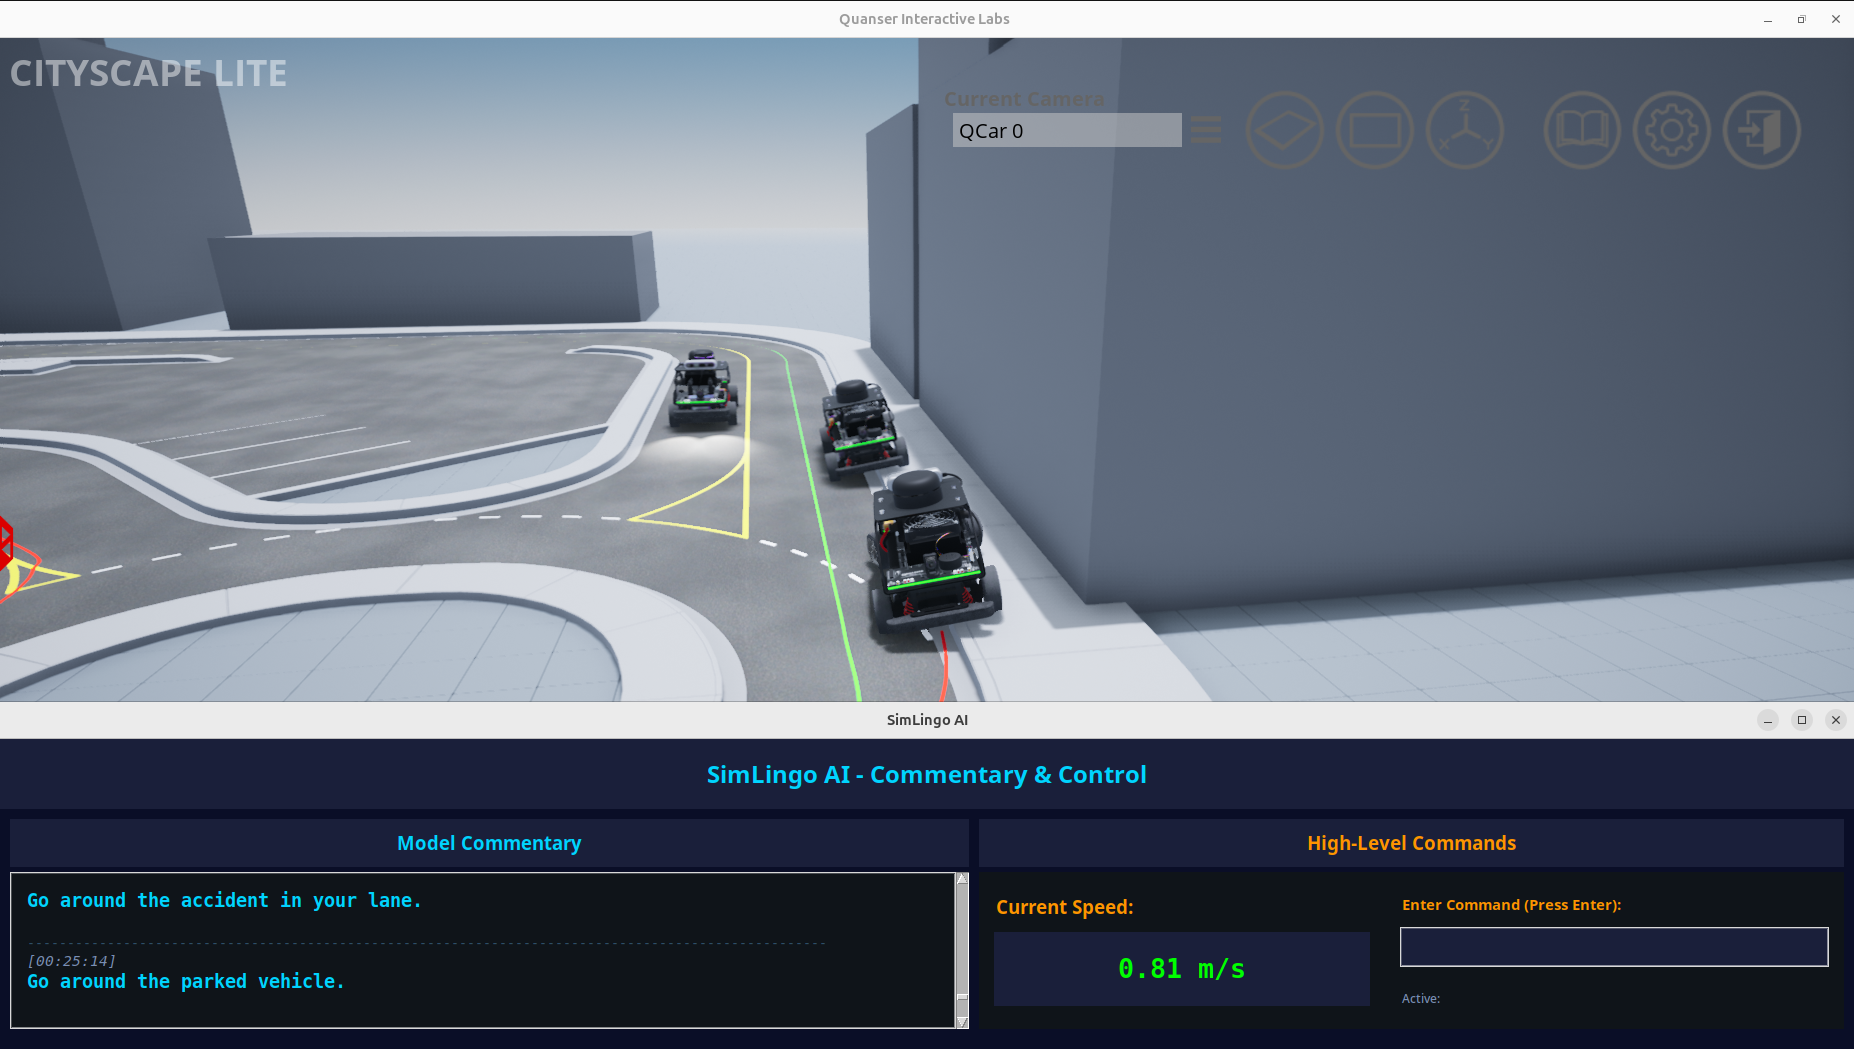
I adapted SimLingo, a vision-language-action driving model trained in CARLA, to Quanser's QLabs digital twin of the QCar 2. Fine-tuned with LoRA on 7,498 expert frames, it raised route coverage from 4.7% to 99.1% in simulation, steering from a single camera at 4 Hz.

99.1% Route coverage, up from 4.7% 0.056 m Lateral deviation (LiDAR baseline 0.261 m) 4 Hz Single-camera control
PyTorch PyTorch Lightning DeepSpeed LoRA / PEFT InternVL2-1B Quanser QLabs
View case study
QCar 2 steering around parked vehicles in the QLabs simulator, with the model's commentary panel below

VR Multicopter Teleoperation

Second author, IEEE AES Magazine (2026)

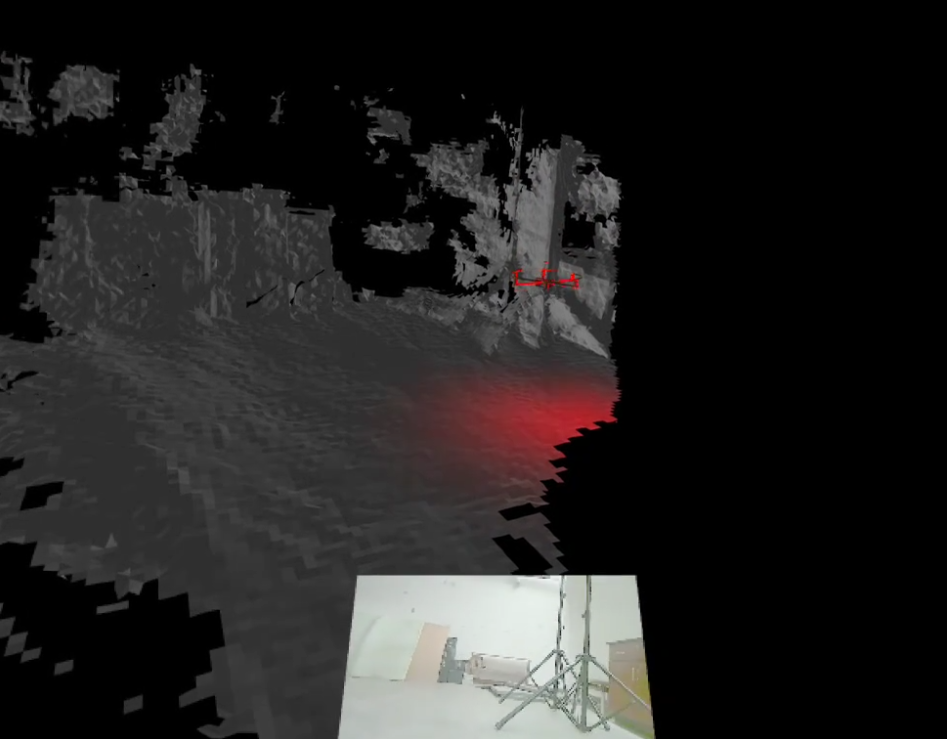
Third-person VR control for a drone. I built the link from WebXR on a Meta Quest 3 to ROS 2 on a Jetson Orin NX running ZED camera SLAM. Across 8 trials, the third-person view kept the drone 0.20 m farther from obstacles than first-person view, at about the same task time.

+0.20 m Obstacle clearance vs first-person 29.8 ms Mean tracking latency (41.9 ms before optimization) 8 Trials compared
WebXR Three.js ROS 2 SLAM Jetson Orin NX ZED
View case study
3D mesh of the test environment with a red drone marker and an inset camera image

Decentralized Drone Swarm Coordination

First author, Aerospace Science and Technology (2026)

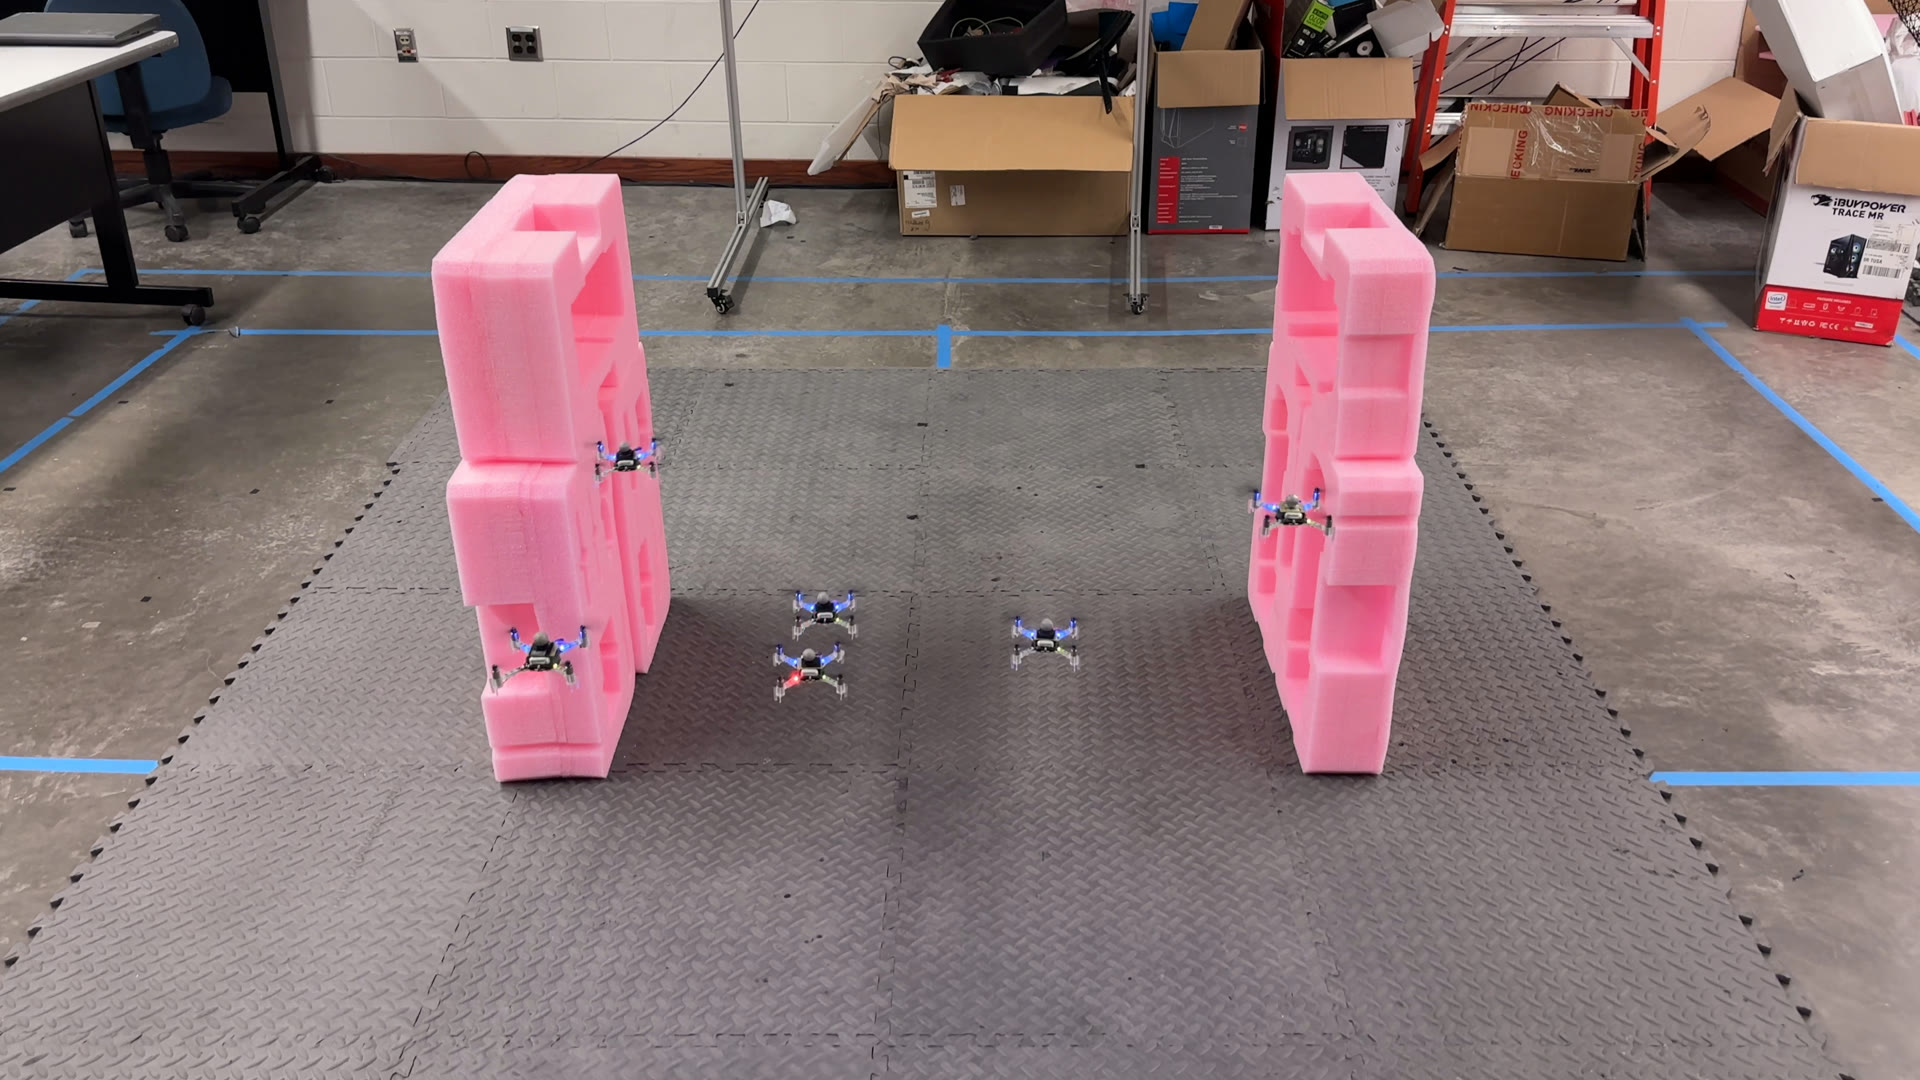
Decentralized formation control for drone swarms. Three leaders follow planned paths, and the followers work out their own positions from their neighbors alone, with no central planner. I flight-tested it on six Crazyflie 2.1 quadrotors under Vicon motion capture.

5.7 cm Leader mean RMSE (followers 8.4 cm) 6 Crazyflie quadrotors 0 Pairs inside the 0.13 m safety threshold
ROS 2 Python Crazyswarm2 Vicon Multi-Agent Systems
View case study
Six Crazyflie quadrotors flying in formation between two stacked foam obstacles

Where I've been.

VP of Engineering and Operations

Araca, Inc.
  • Own the Araca Insights product line: roadmap, architecture, releases, licensing and first-line support
  • Lead the Slurry Flow Visualization program, which turns 4K, 240 fps polishing video into flow measurements with OpenCV and SAM 2.1
  • Own revenue for two business units, from first contact to signed contract and renewal; supervise two lab staff and hire and train engineers

Software Engineer, Data Automation and Analytics

Araca, Inc.
  • Built Araca Insights from scratch: an offline desktop app that imports CMP test-stand data, plays back runs, compares and correlates them, and exports Excel and PowerPoint reports
  • Trained process-prediction models with scikit-learn and FLAML AutoML, and built an on-premises LLM agent (LangChain, Ollama) that answers plain-language questions about the data
  • Shipped it as a licensed product: Nuitka-compiled Windows binaries, an Inno Setup installer and Ed25519-signed node-locked license keys

Consulting Robotics Engineer

LOCH Technologies (contract, remote)
  • Built the camera and onboard-compute side of a counter-UAS interceptor drone: Raspberry Pi 5, Pi Camera Module 3, Pixhawk running ArduPilot over MAVLink, and ROS 2
  • Proposed proportional-navigation guidance for the intercept and drafted the onboard compute hardware plan
  • Handed the configured prototype to the team at the end of the contract

Robotics Researcher

SmartLab, University of Arizona
  • Built and flight-tested a decentralized formation controller on six Crazyflie 2.1 quadrotors: 5.7 cm mean RMSE for leaders, 8.4 cm for followers, and no pair inside the 0.13 m safety threshold
  • Built a VR drone teleoperation system on a Meta Quest 3 and a Jetson Orin NX; across 8 trials the third-person view kept the drone 0.20 m farther from obstacles at about the same task time
  • Flew a 10-drone Crazyflie swarm on two Crazyradio 2.0 radios for a paper in preparation

Software Engineer Intern

Aeyesafe (remote)
  • Wrote the Python backend logic that turns incoming IoT sensor messages into real-time alerts
  • Set up user authentication with AWS Cognito and API Gateway, with Lambda functions, SQS queues and DynamoDB storage
  • Containerized the services with Docker and automated testing and deployment with Bitbucket Pipelines

Teaching Assistant and Course Coordinator

University of Arizona, Computer Science
  • Coordinated an introductory computer science course across multiple sections
  • Led weekly labs and office hours for 300+ students
  • Built a real-time coding-practice platform (React, Node.js, PostgreSQL) that gave students instant feedback on exercises

M.S. and B.S. Computer Science

University of Arizona
  • M.S., Aug 2025 - May 2026. Thesis: Adapting Vision-Language-Action Models to New Domains: A Case Study with SimLingo on QCar 2
  • B.S., magna cum laude, Aug 2022 - May 2025. Minor in Systems and Industrial Engineering
  • Runner-up in the Amazon AWS Challenge at Hack Arizona 2025 (150+ teams); $7,000+ in NSF I-Corps and UA Forge startup grants

Deputy Director for Commercial Affairs

AgroPetro, Krasnodar Krai, Russia
  • Directed commercial strategy and operations for a food manufacturing group of about 500 employees
  • Managed a direct team of 50+ sales representatives
  • Grew annual revenue 150% from 2019 to 2021 through data-driven sales planning and process changes

What I've published.

Aerospace Science and Technology, 2026

First author, with H. Rastgoftar. "Decentralized Affine Transformation for Scalable and Safe Multi-Agent Aerial Coordination." Vol. 180, art. 113539.

IEEE Aerospace and Electronic Systems Magazine, 2026

Second author, with J. T. Hughes, M. Ghufran and H. Rastgoftar. "VR-Based Control of Multicopter Operation." 41(2):46-55, Feb 2026.

M.S. thesis, University of Arizona, 2026

"Adapting Vision-Language-Action Models to New Domains: A Case Study with SimLingo on QCar 2." Committee: Chicheng Zhang and Hossein Rastgoftar (co-chairs), Eduardo Blanco.

Peer review

Reviewer for IEEE Transactions on Automation Science and Engineering (T-ASE): 2 manuscripts in 2026.

Let's build something intelligent.

Working on ML, computer vision or robotics software? I'd like to hear about it.